Mosaic
An Extensible Framework for Composing Rule-Based and Learned Motion Planners
1Karlsruhe Institute of Technology (KIT), Karlsruhe, Germany · 2FZI Research Center for Information Technology, Karlsruhe, Germany · *Authors have equal contribution
Abstract
Safe and explainable motion planning remains a central challenge in autonomous driving. While rule-based planners offer predictable and explainable behavior, they often fail to grasp the complexity and uncertainty of real-world traffic. Conversely, learned planners exhibit strong adaptability but suffer from reduced transparency and occasional safety violations. We introduce Mosaic, a framework for structured decision-making that integrates both paradigms through arbitration graphs. By decoupling trajectory verification and selection from the generation of trajectories by individual planners, every decision becomes transparent and traceable. This separation lets verification and trajectory selection contribute independently: centralized verification acts as a safety floor, reducing at-fault collisions from 25 for each standalone planner to 16. In contrast, per-step trajectory selection acts as a performance ceiling, combining the complementary strengths of a rule-based and a learned planner. In experimental evaluation on nuPlan, Mosaic achieves 95.56 CLS-NR and 94.18 CLS-R on the Val14 closed-loop benchmark, setting a new state of the art. On the interPlan benchmark, focused on highly interactive and out-of-distribution scenarios, Mosaic scores 54.10 CLS-R, outperforming its best constituent planner by 22.8% — all without retraining or requiring additional data.
Poster
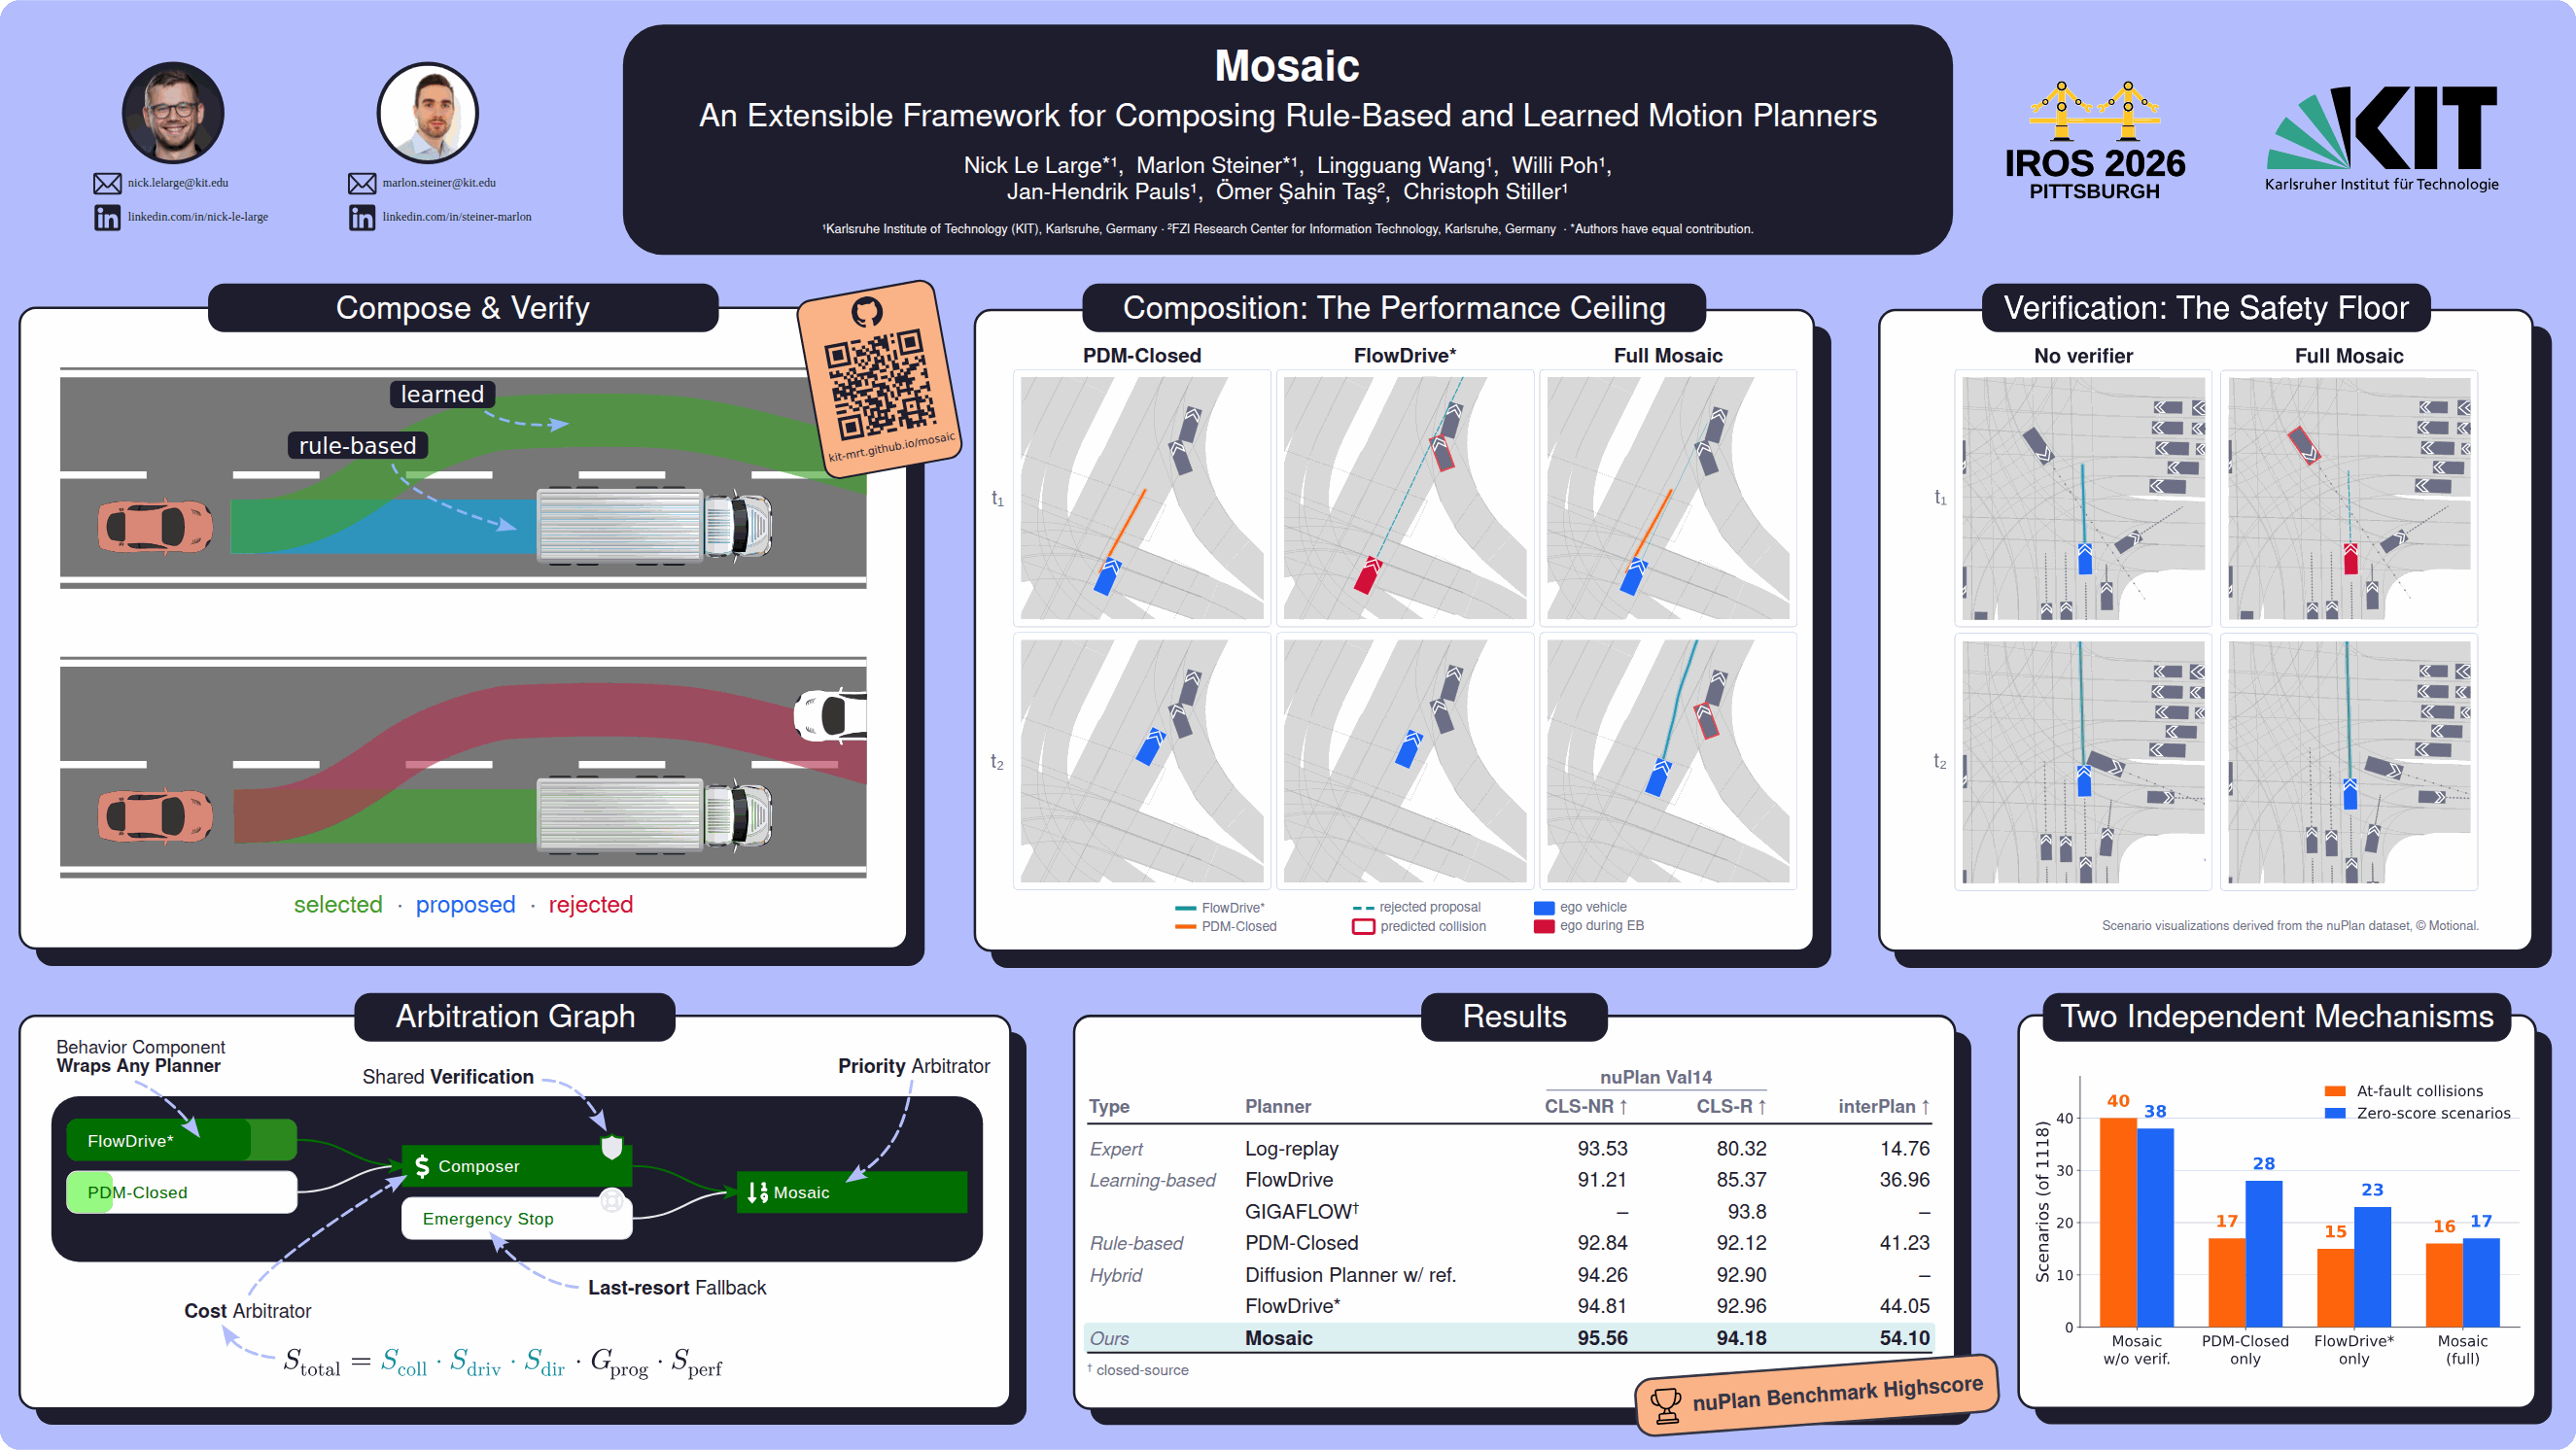
Click the poster to download the PDF.
Scenarios
PDM-Closed alone stops behind a blocked lane. For FlowDrive*, this is an out-of-distribution scenario. It destabilizes and stalls too. Composing both lets Mosaic stabilize the approach using PDM-Closed giving FlowDrive* time to propose the lane change around it.
Cite
@misc{lelarge2026mosaic,
  title={Mosaic: An Extensible Framework for Composing Rule-Based and Learned Motion Planners},
  author={Le Large, Nick and Steiner, Marlon and Wang, Lingguang and Poh, Willi and Pauls, Jan-Hendrik and Ta\c{s}, {\"{O}}mer {\c{S}}ahin and Stiller, Christoph},
  year={2026},
  eprint={2604.13853},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2604.13853},
}
Contact