Placeholder
Your paper here
Using Lanelet2 in a paper or project? Open an issue or a pull request on this website’s repo to get it listed.
Papers, theses, and projects that adopt Lanelet2 in robotics and autonomous driving research.
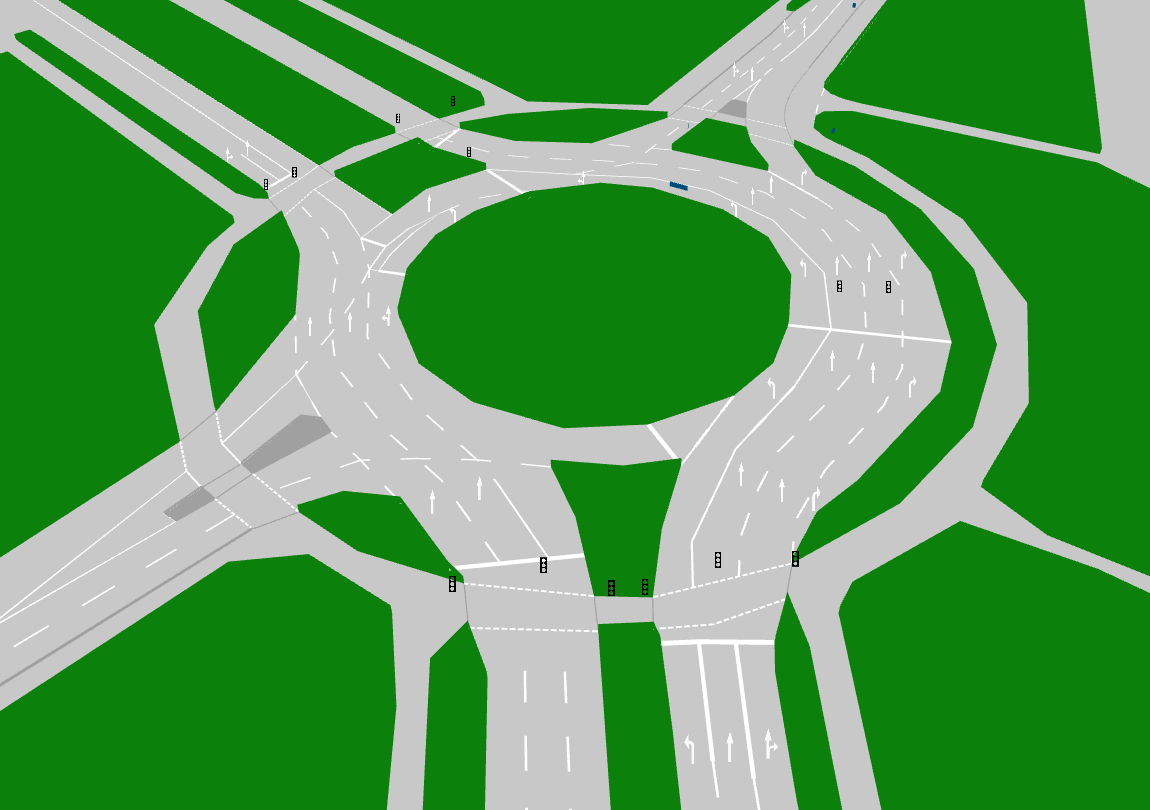
© Poggenhans et al. / FZI & KIT, 2018
Fabian Poggenhans, Dr.-Ing. dissertation, KIT (2019, CC BY-SA 4.0): methods to generate HD maps from vehicle sensors, evaluated on 102 km around Karlsruhe.
KIT library ↗Using Lanelet2 in a paper or project? Open an issue or a pull request on this website’s repo to get it listed.