© KIT-MRT / KITScenes
KIT Autonomous Driving Project
Lanelet2 is powering both the KIT in-house AD Stack as well as Autoware running on two research vehicles in weekly close-loop testdrive operations. Learn more at the KIT-MRT CITI project page.
Research from our groups that builds on Lanelet2 — converters, map learning, and more.
© KIT-MRT / KITScenes
Lanelet2 is powering both the KIT in-house AD Stack as well as Autoware running on two research vehicles in weekly close-loop testdrive operations. Learn more at the KIT-MRT CITI project page.
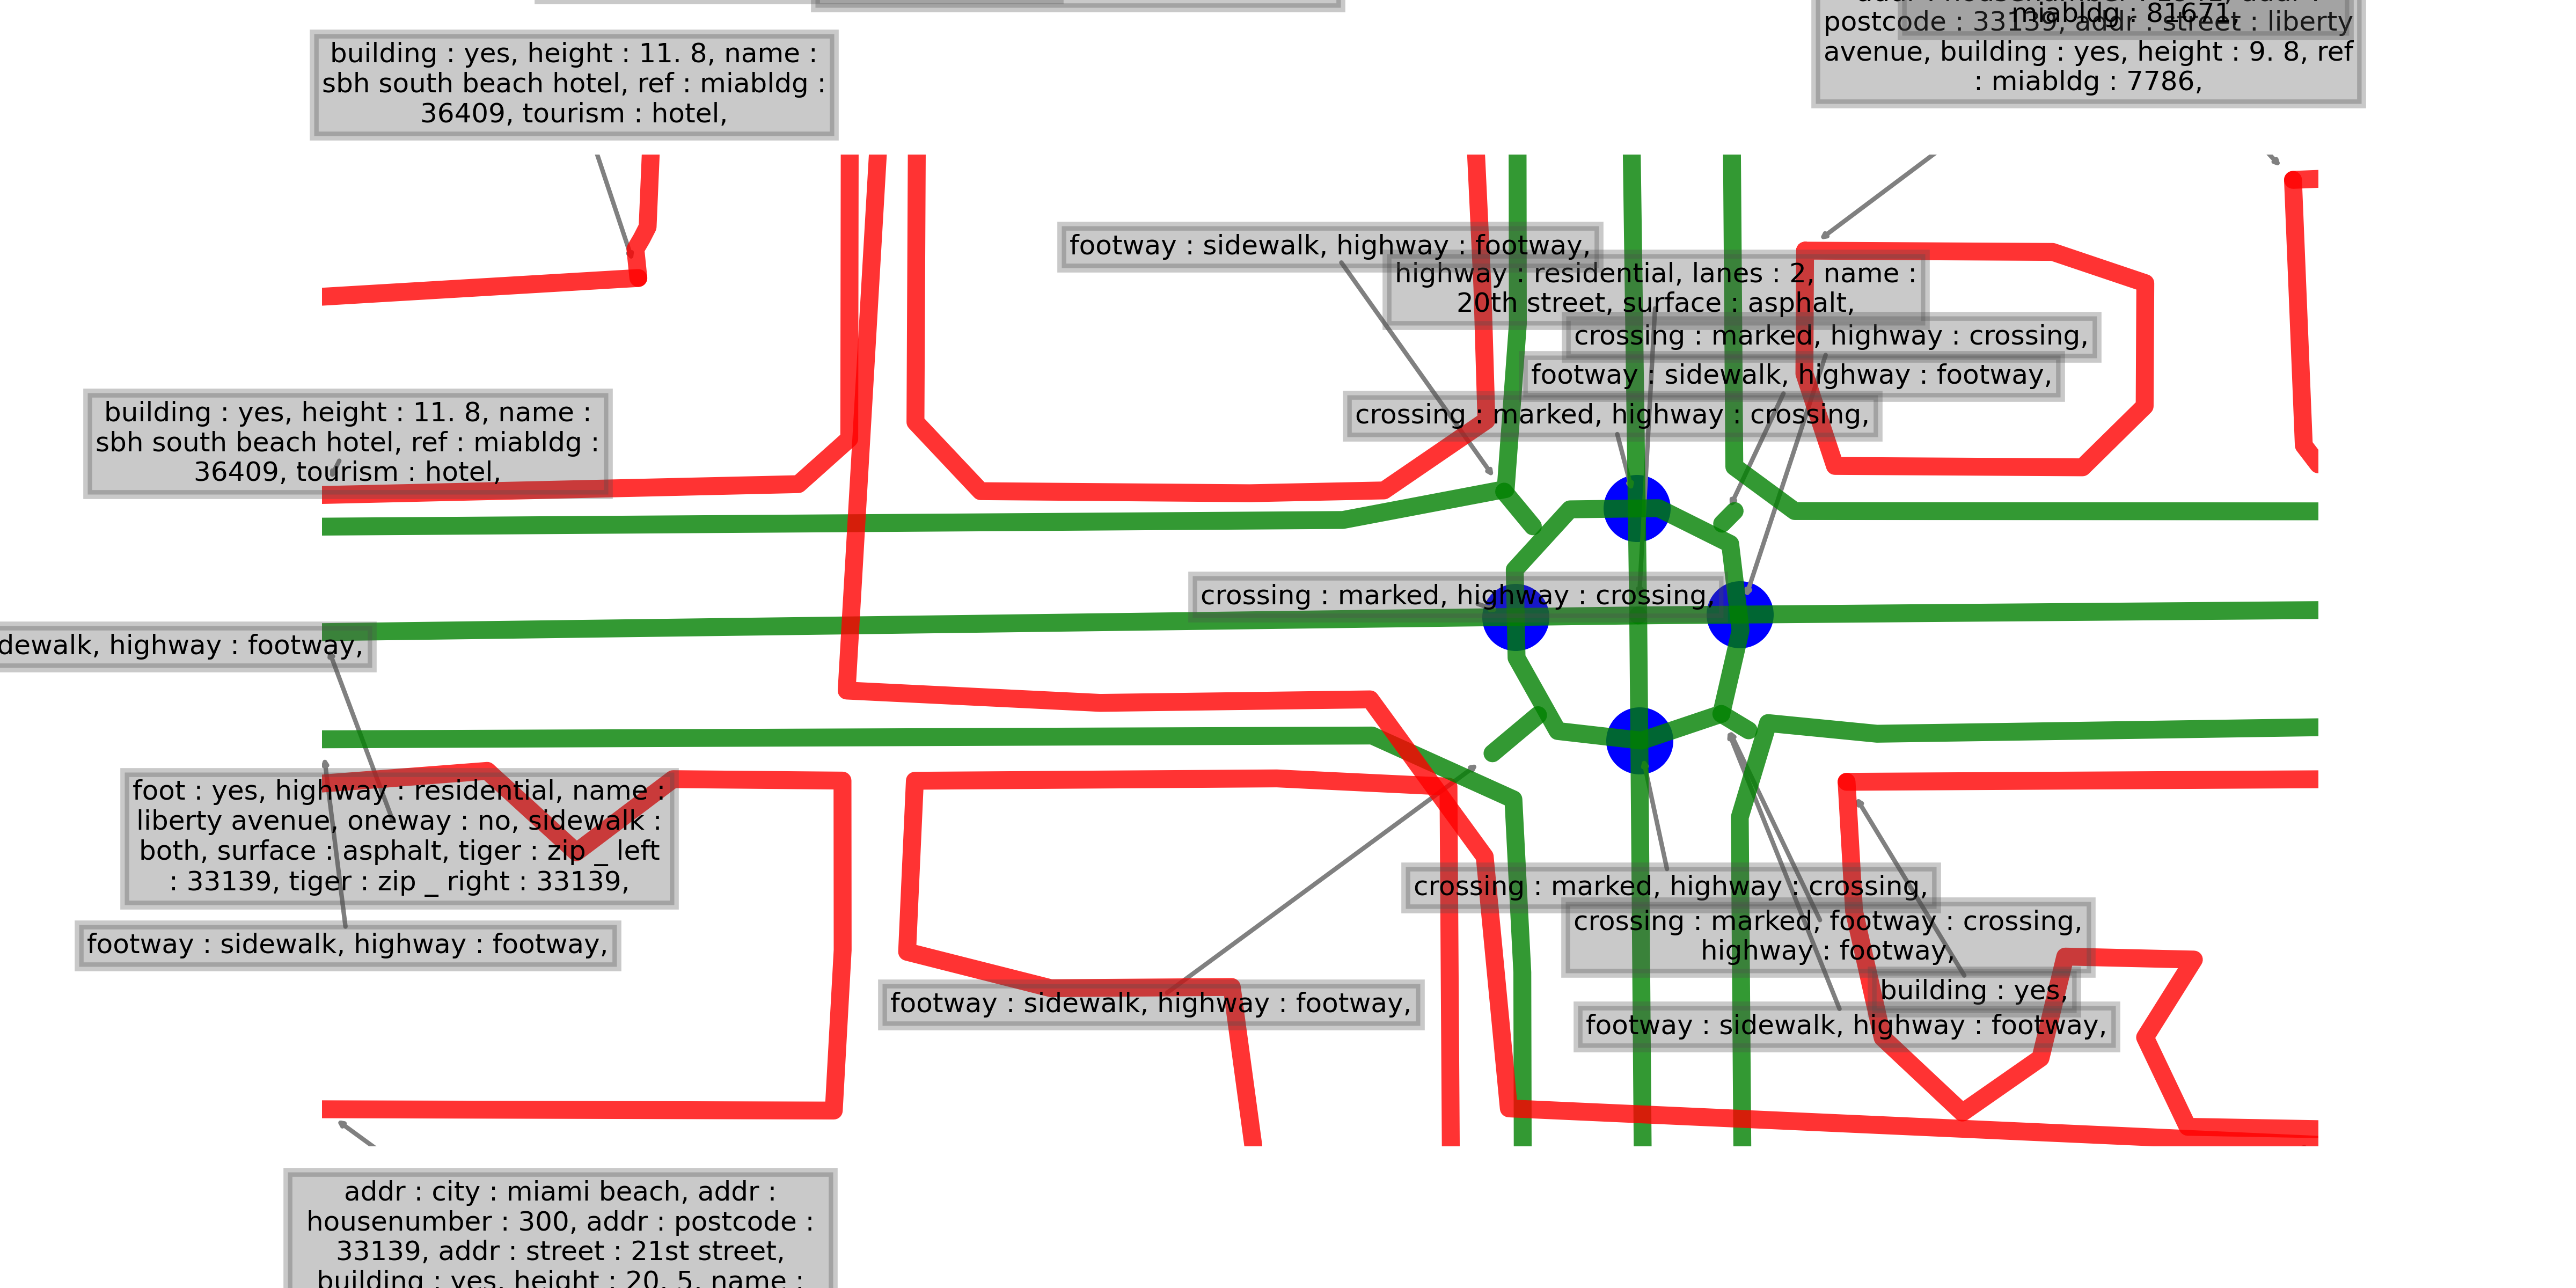
© Immel et al., NeurIPS 2025. Map © OpenStreetMap contributors
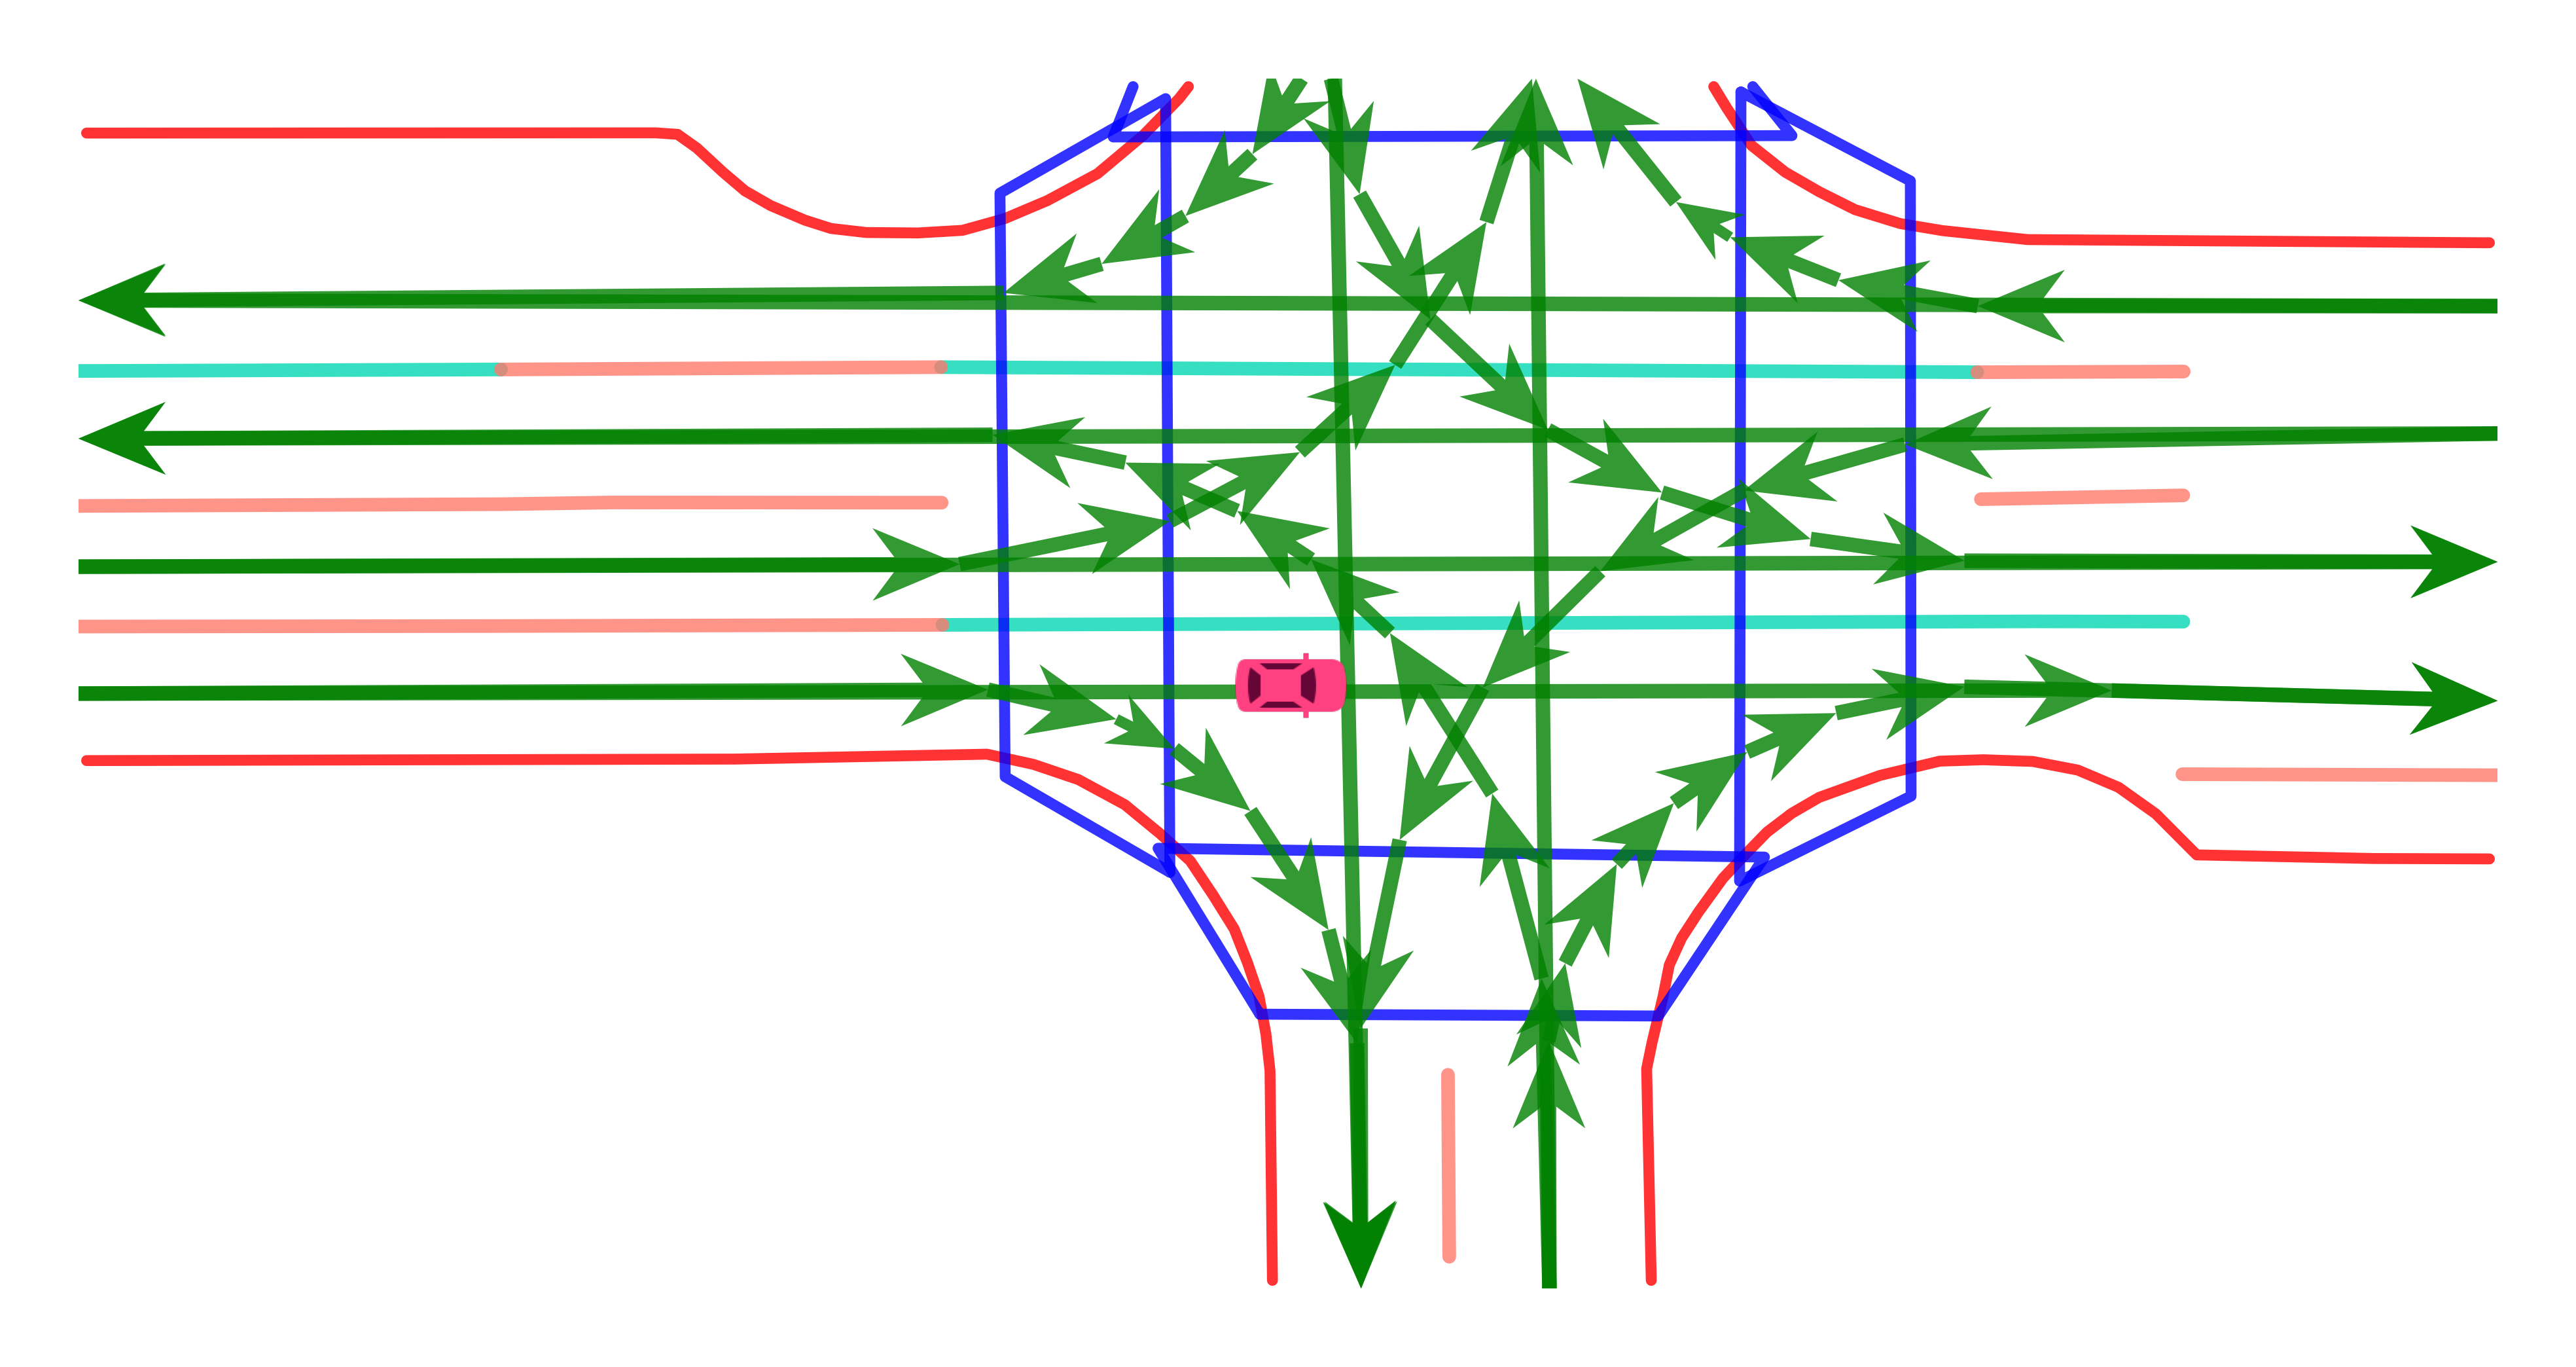
© Immel et al., IEEE RA-L 2025